


Core Technology
The ecosystembehind each solution

- .01Tele™OperatorRemote Control
- .02Micro™PilotAutonomous
- .03Mission™PlannerBusiness
- .04Fleet™ManagerLarge Operation
- .05Micro™OSIntegrated HW


Remote Control

Command and control center that provides the operator with real-time access to the robot
Real-time telemetry
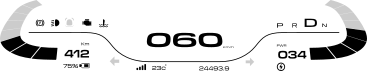
Onboard systems
Control

System Health
Live surround view

Safety warnings
Driving modes

Real-time streaming
Low latency
- 5G
- RADIO
PTZ Camera control

Multi-support RC inputs
- +Keyboard
- +Joystick
- +Customized Station

Map Nav

Diagnostics
Autonomous driving
The autonomy system behind our robots, developed end to end in house. Sensing, localization, perception, prediction, planning and control
GatedStack™


Where the constraint isn't speed, it's people. Few traffic rules apply and nobody is obliged to follow a lane. The vehicle keeps continuous close-range awareness in every direction, holds onto objects through the moments they're obscured, and treats everyone nearby as free to change direction at any time. The result is a vehicle that moves smoothly through shared space rather than hesitating at every pedestrian.
UrbanStack™

The stack reasons about intent, predicting how road users will move and how that meets its own plan. A road understanding layer establishes the rules in force at any moment, lane structure and right of way, by checking prior map knowledge against live observation rather than trusting either alone. Planning then works within those rules the way an attentive driver does, negotiating traffic instead of merely avoiding it.
Off-roadStack™

Off-road there are no lanes, no boundaries and no map, so the vehicle reasons about the terrain instead. It continuously judges the ground ahead: what the surface is, whether it will hold the vehicle, and what else is moving across it. Routes are chosen on that basis rather than on road structure. The result is a vehicle that works in dust, over broken ground, and across terrain nobody has surveyed.
Operations, designed

Enables operators to design, schedule, and manage autonomous vehicle missions
Route design
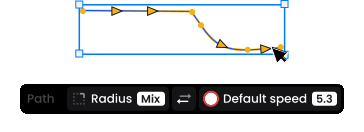
Mission schedule

Add-ons
- +Supports for different maps
- +Multi-user route edit
- +Customized rules per goal
Rule-base goals

Mission simulation

Custom traffic rules

Scale up with fleets

Centralized visibility and operational oversight across the entire robotic fleet

Fleet bird-eye view
Custom Integrations
- +ERP systems
- +Assets management
- +Fleet management
Seamless robot onboarding

Maintenance Schedule

Orchestration behind the scene
One operating system powers everything above. Our own robotics OS, shaped end to end, from the kernel to over-the-air updates
Purpose-built
Linux distribution
- +One image per robot, built for its role
- +Only what the application needs
Robotics at the edge
GPU accelerated
- CUDA
- cuDNN
- TensorRT
- ROS 2
Every interface native
Kernel-level drivers
- +CAN bus
- +Serial & USB
- +Ethernet
Fail-safe updates
Over the air
- ENCRYPTED
- VERIFIED
Built for developers
- +SDK cross-compiled per robot
- +Develop and test with no hardware in hand
Actionable operational awareness
Our detection and behavioral intelligence platform
